Modicon M310
- Type
- EtherCAT motion controller
- Applications
- Multi-axis packaging, electronics, robotics equipment
- Scale / I/O
- 8-64 axes
- Communication & motion
- EtherCAT, CANopen, Ethernet
- Engineering software
- Motion Expert
Schneider Electric · Modicon
EtherCAT motion controllers for multi-axis packaging, electronics and robotic machinery.
This page supports platform, model, I/O and engineering-architecture identification. Confirm the full designation against supply, signal types, networks, expansion modules, software and firmware versions.
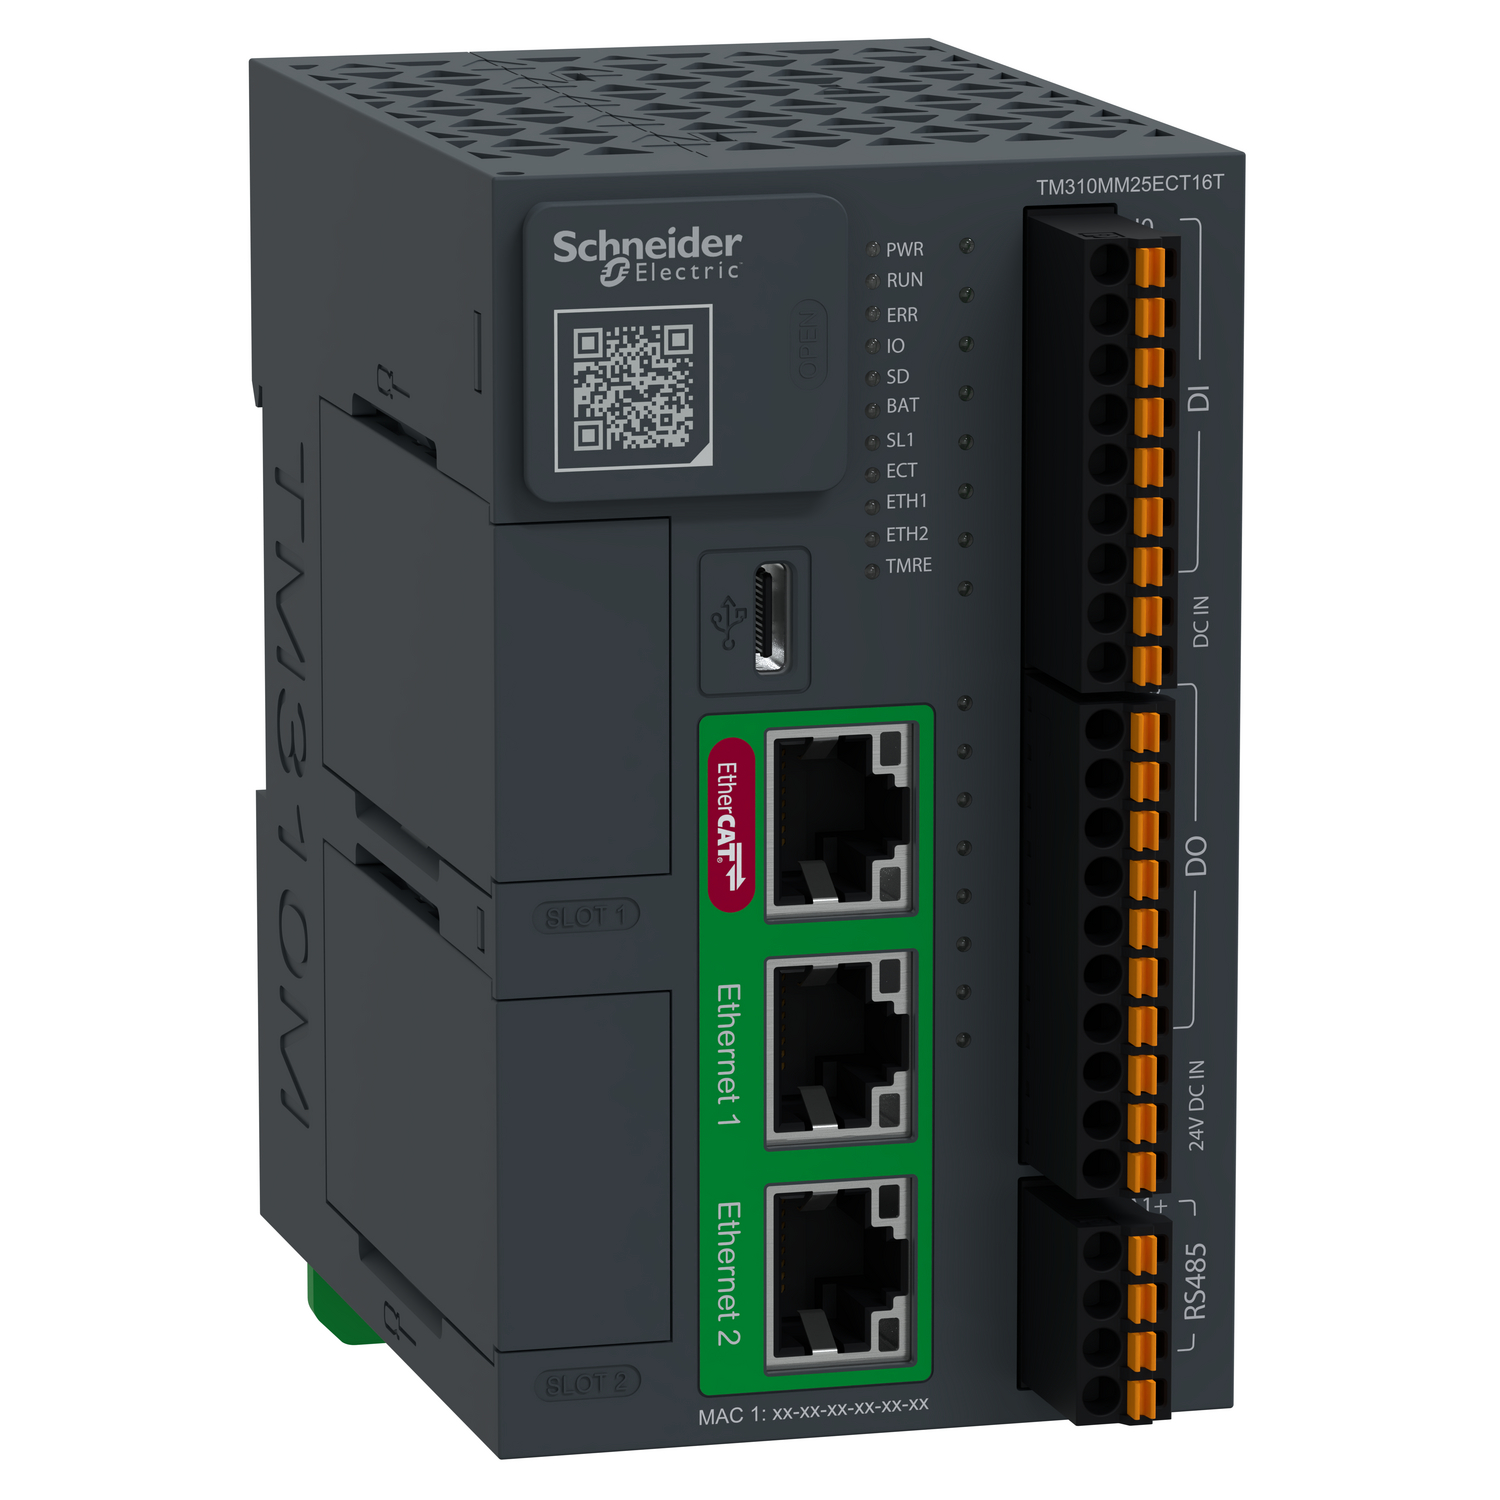
PRODUCT OVERVIEW
EtherCAT motion controllers for multi-axis packaging, electronics and robotic machinery.
The page retains controller, expansion-I/O, software and model-code information so the review can continue against the actual control architecture.
PLATFORM STRUCTURE AND CORE CAPABILITIES
EtherCAT motion controller
8-64 axes
EtherCAT, CANopen, Ethernet
Motion Expert
TECHNICAL DATA AND PLATFORM BRANCHES
CONTROLLER REFERENCES
Confirm supply, I/O, electrical outputs, networks, expansion, software and firmware before finalizing the order number.
| Model | Controller type | Supply | Embedded I/O | Output type | Ethernet | Fieldbus / motion | Program / performance | Expansion scale | Software |
|---|---|---|---|---|---|---|---|---|---|
| TM310MM25ECT16T | M310M PLC-type motion controller | 24 Vdc (per hardware guide) | 8DI + 8DO PNP | High-speed transistor | Yes | EtherCAT, Ethernet, RS485 | 8 axes | 8-64 axes of synchronized motion control, depending on model | EcoStruxure Motion Expert |
| TM310MM35ECT16T | M310M PLC-type motion controller | 24 Vdc (per hardware guide) | 8DI + 8DO PNP | High-speed transistor | Yes | EtherCAT, Ethernet, RS485 | 16 axes | 8-64 axes of synchronized motion control, depending on model | EcoStruxure Motion Expert |
| TM310MM35ECT16U | M310M PLC-type motion controller | 24 Vdc (per hardware guide) | 8DI + 8DO NPN | High-speed transistor | Yes | EtherCAT, Ethernet, RS485 | 16 axes | 8-64 axes of synchronized motion control, depending on model | EcoStruxure Motion Expert |
| TM310M35ECT26T | M310 PC-type motion controller | 24 Vdc (per hardware guide) | 18DI + 8DO | High-speed transistor | Yes | EtherCAT, Ethernet, serial, CANopen, encoder | 16 axes / 0.25 ms | 8-64 axes of synchronized motion control, depending on model | EcoStruxure Motion Expert |
| TM310M45ECT26T | M310 PC-type motion controller | 24 Vdc (per hardware guide) | 18DI + 8DO | High-speed transistor | Yes | EtherCAT, Ethernet, serial, CANopen, encoder | 32 axes / 0.5 ms | 8-64 axes of synchronized motion control, depending on model | EcoStruxure Motion Expert |
| TM310M55ECT26T | M310 PC-type motion controller | 24 Vdc (per hardware guide) | 18DI + 8DO | High-speed transistor | Yes | EtherCAT, Ethernet, serial, CANopen, encoder | 64 axes / 1 ms | 8-64 axes of synchronized motion control, depending on model | EcoStruxure Motion Expert |
ENGINEERING SOFTWARE
| Software | Controller ranges | Project type | Integration | Version notes | Migration notes |
|---|---|---|---|---|---|
| EcoStruxure Motion Expert | M310 | EtherCAT multi-axis motion projects | EtherCAT, CANopen, encoder, Ethernet | Software and controller firmware must match | Legacy motion projects require re-testing of synchronization cycle |
MODEL-CODE GUIDE
| Code | Meaning | Example | Verify |
|---|---|---|---|
| M/MM + axis class | Distinguishes PC-type/PLC-type and motion capability | TM310M45ECT26T | Axis count, cycle, and I/O should be confirmed together |
INQUIRY CHECKLIST
PLATFORM SUMMARY
APPLICATIONS
Review program size, scan cycle, networks, motion control and machine-safety requirements.
Define the architecture around availability, redundancy, remote I/O, communications and engineering software.
Structure the control system around I/O scale, network topology and maintenance.
Begin migration review with the original program, module list, firmware, networks and wiring.
RECOMMENDED PLATFORM RANGES
EtherCAT motion controller
This is a platform overview, not a complete system selection. Verify the final configuration against the full catalog number, program, I/O, electrical, network, software, firmware and mechanical conditions.
 Message on WhatsApp